
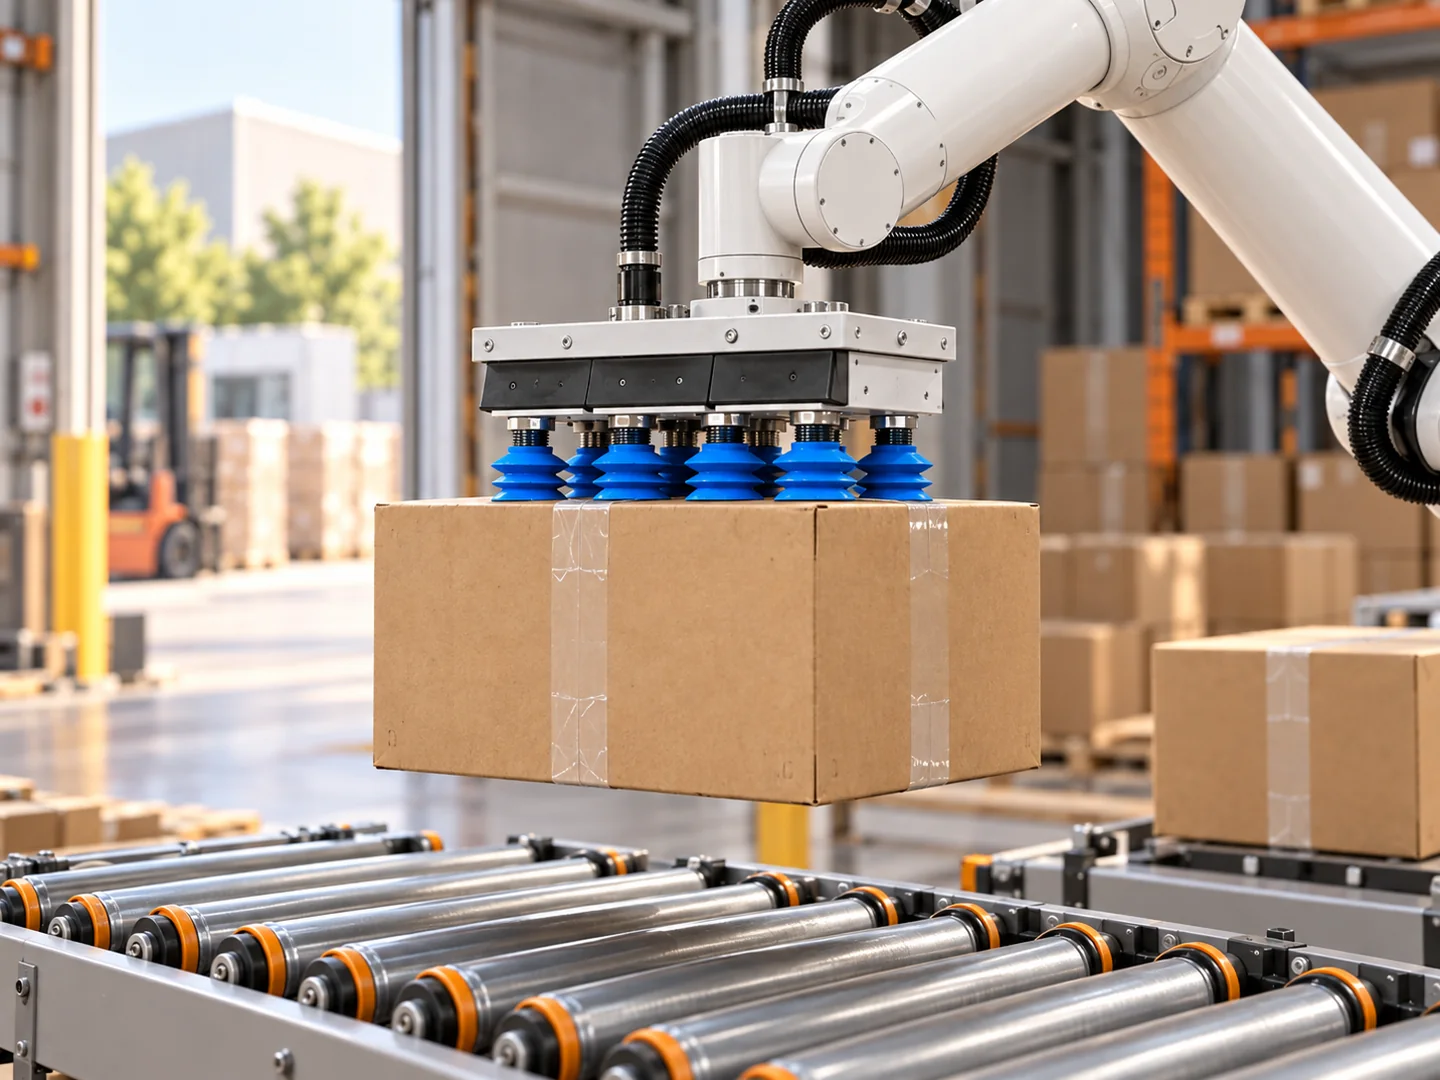
A robot payload calculation starts with everything carried at the tool flange: the gripper assembly, adapters, attached equipment and the workpiece. In carton handling, the filled box mass is only one part of that load.
The calculation below produces a mass and combined centre of gravity. It does not establish an approved working load. Check the resulting arrangement against the selected robot and tooling manufacturers’ requirements, including inertia and the intended motion.
Gather the complete load data
Use filled carton weights and the actual assembled tool. Include the mounting adapter, valves or sensors attached to the tool, support shelves and other carried components. Treat utility routing according to the robot manufacturer’s load-modelling instructions.
Record each component’s centre of gravity relative to the same coordinate origin, usually the manufacturer-defined tool-flange frame. CAD mass properties can help, but the model must represent the assembled equipment and contents accurately.
Universal Robots’ maximum-payload documentation identifies gripper and workpiece mass, centre-of-gravity offset and inertia as relevant to its robot load configuration. Apply the manual for the specific robot under review.
Calculate the combined mass
For a group of attached components:
Total carried mass = sum of the component masses
Hypothetical example: an assembled vacuum tool weighs 6 kg and a filled carton weighs 12 kg. Assume that the tool figure already includes its adapter and attached sensors. The total loaded mass is 18 kg.
The empty-tool state is 6 kg. The loaded state is 18 kg. Both states belong in the application data, with the applicable centre of gravity and inertia for each.
Calculate the combined centre of gravity
For each coordinate axis, use the mass-weighted average of the component positions:
Combined coordinate = sum of (component mass × component coordinate) ÷ total mass
Take a simplified example in which both component centres lie on one axis measured from the flange. The 6 kg tool’s centre is 0.10 m from the origin. The 12 kg carton’s centre is 0.35 m from it.
Combined offset = ((6 × 0.10) + (12 × 0.35)) ÷ 18 = 0.267 m, approximately
| Component | Mass | Assumed axis offset | Mass × offset |
|---|---|---|---|
| Complete tool | 6 kg | 0.10 m | 0.60 kg·m |
| Filled carton | 12 kg | 0.35 m | 4.20 kg·m |
| Combined | 18 kg | About 0.267 m | 4.80 kg·m before division |
This is a one-axis teaching example. A real assembly needs all relevant axes, correct frames and the manufacturer’s required inertia data. The example does not select a robot or approve this tool arrangement.
Check the manufacturer’s load envelope
A headline payload rating cannot settle whether the calculated load is permitted at its offset and inertia. Obtain the load diagrams and configuration instructions for the exact robot model, tool orientation and operating conditions.
Review the actual extraction and placement positions. Tool orientation, the position of the carton and its changing relationship to the wrist can matter to the motion and clearances. Check the planned path with the intended load data rather than an unloaded simulation alone.
If the carton contents move, its centre of gravity may differ from the geometric centre of the outer box. Include that uncertainty in the application review and representative testing.
Keep payload and grip capacity separate
An acceptable robot load does not prove that the tool can retain the carton. Vacuum leakage, carton-panel strength, side forces and release behaviour need their own assessment.
Use the suction cup force calculation guide for the distinction between a theoretical suction force and a tested grip. The EOAT checklist covers mounting, utilities and confirmation signals.
Use a project worksheet
Before selecting equipment, record:
- maximum filled carton mass and its variation;
- complete tool mass, including adapters and attachments;
- component centres of gravity in one defined frame;
- combined mass, centre of gravity and required inertia data;
- manufacturer load limits and planned motion;
- grip tests, clearances and acceptance observations.
KRONA U1’s up-to-25-kg closed-carton limit is an application specification for the complete system. It is not a robot-wrist payload rating or a basis for changing its tooling.
Send representative cartons and handling geometry when assessing a complete unloading project. For a client’s downstream palletizing cell, include the cell layout requirements as well.
- end of arm tooling
- cardboard cartons
- system integration
KRONA U1 unloads boxes from containers onto pallets or conveyors and also loads containers with boxes from pallets or conveyors. Explore KRONA U1 →
Assess your cartons and handling geometry