Perception
Image and depth data become a current model of the workspace and freight.
KRONA U1 plans every pick from the current state of the freight. Perception, planning, and robot-control software run in one closed loop, while safety functions remain separate.
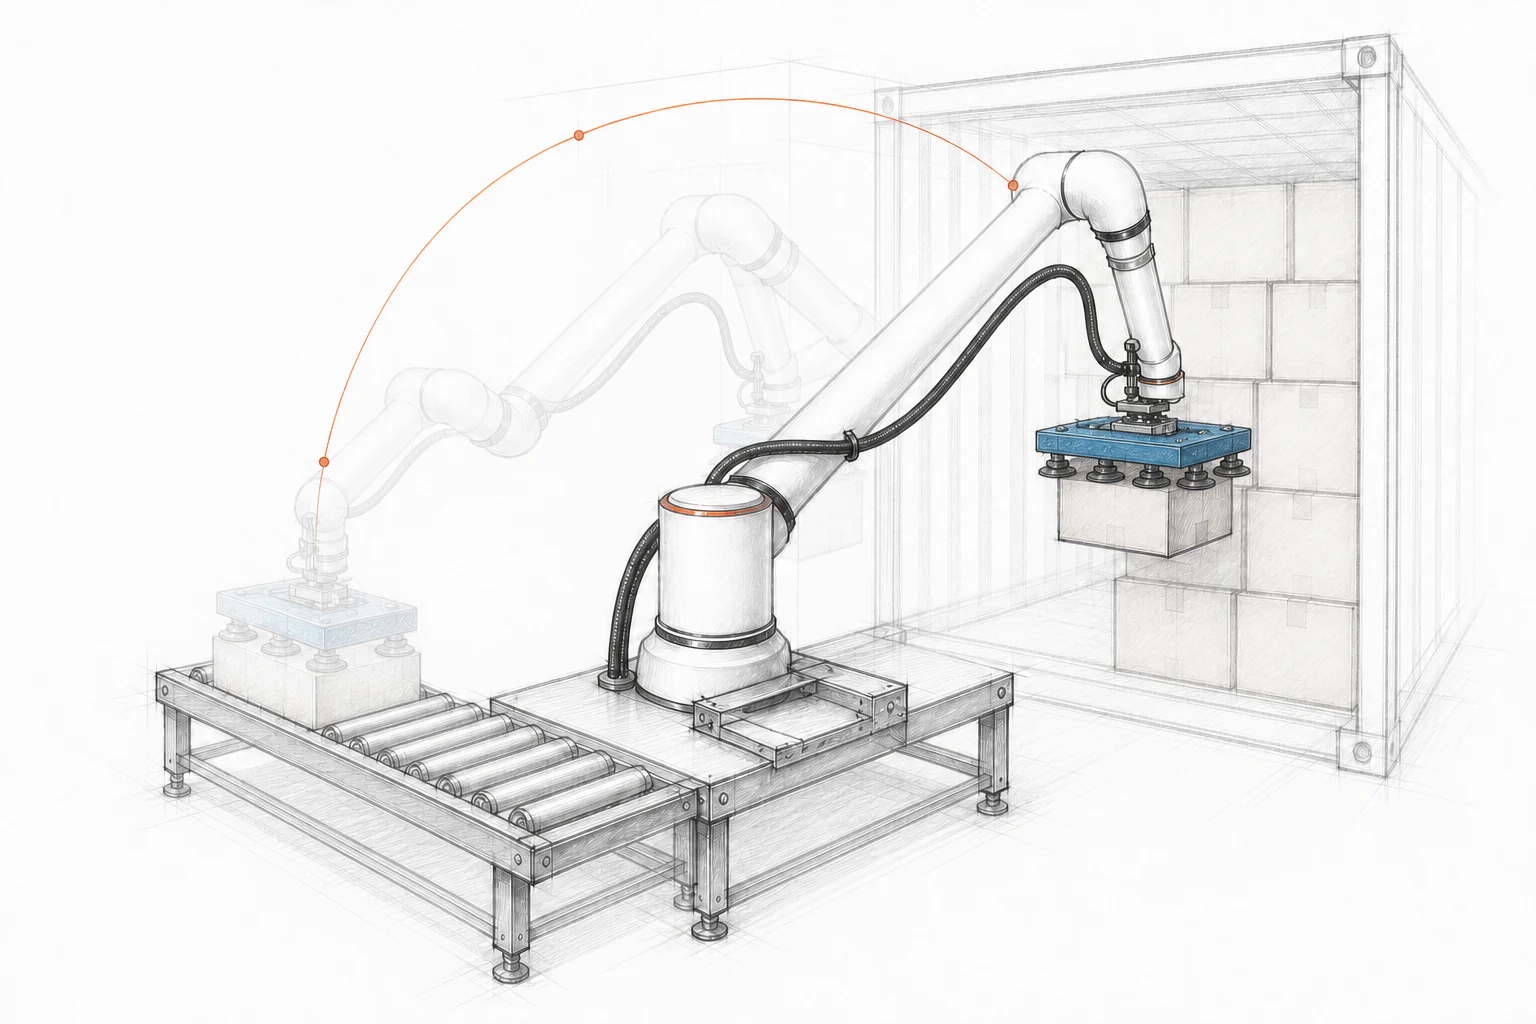
The freight scene changes after every box is removed. The system therefore observes the workspace again before planning its next action.
Cameras and depth sensors refresh the view of the workspace.
Software selects a suitable box, contact point, and motion path.
The robot and end effector execute the planned movement.
The outcome returns to the next assessment of the scene.
Clear responsibilities make it possible to see where the system perceives the scene, makes a decision, and controls physical motion.
Image and depth data become a current model of the workspace and freight.
The system evaluates possible picks and selects an allowable robot trajectory.
Robot and tool commands are executed while the actual system state is monitored.
Autonomy software decides what to do next. Work zones, access control, and stopping functions are designed separately for the specific site.
Exact safety measures and system boundaries are defined during the site assessment.
When the system cannot reasonably continue, it gives an operator the relevant context. Work resumes only after an appropriate action is selected and the system is in an allowable state.
System states, stops, and operator interventions are recorded for analysis. Software changes are verified before they reach the working environment.
Start with box samples, your current unloading process, and basic dock dimensions.